Safety
Sufficient temporal separation keeps agents collision-free as they traverse shared regions.
Safe emergent coordination in shared spaces.
Robots learn from local motion and continuously adapt their decisions. Safe passage emerges through interaction, without communication or preassigned priorities.
Collision avoidance alone does not ensure that robots get through a crowded space. At a bottleneck or crossing, robots can keep yielding to one another or repeatedly change their decisions without making progress. The challenge is to establish a consistent passage order while conflicts overlap and groups change, using only local sensing.
NDD links each robot’s internal decision and attention states to its physical motion. A robot follows its prescribed path and continuously adjusts its speed in response to nearby agents’ relative positions and velocities. As conflict becomes urgent, feedback between decisions and motion amplifies small timing differences, breaks indecision, and establishes a traversal order within the engaged group.
The order persists while conflicts clear. Groups can split or merge, and robots return to nominal motion when interaction is no longer needed. The controller requires no communication, preassigned priorities, or models of neighbors’ intended actions. The paper derives explicit conditions for safe passage, continued progress, and robustness.
Online learning & adaptation
Who matters, who yields, and who moves first emerge from the ongoing interaction.
Interaction weights are learned and continuously adapted from real-time motion cues, focusing each agent’s attention on the conflicts that matter now.
Decision–action feedback amplifies small differences in motion into a coordinated traversal order. Agents adjust their speed while preserving their paths.
Groups form, split, and merge. Decisions evolve with new conflicts and relax as conflicts clear, restoring nominal motion.
Explore the same interaction mechanism in aerial traffic, road intersections, and warehouse navigation. Select a domain below, then follow the motion and decision traces in each recorded experiment.
Fifteen aerial vehicles adapt speed and altitude through intersecting routes.
Drag to rotate · scroll to zoom · scrub the timeline
The central result
Local sensing and feedback give rise to safe passage and continued progress across changing groups.
Sufficient temporal separation keeps agents collision-free as they traverse shared regions.
A consistent traversal order resolves conflicts in finite time, without deadlock or livelock.
Explicit margins accommodate bounded sensing, motion-prediction, and actuation errors.
The paper gives joint conditions on sensing range, feedback gains, response time scales, actuation limits, and admissible conflict geometry. Fixed local parameters are independent of total population and realized group size. Guarantees apply to cooperative NDD-controlled populations within the stated assumptions, including finite conflict recurrences per episode.
The aerial speed/altitude demonstrations and cooperation-inference extension illustrate further applications; their displayed trials do not extend the paper’s theorem to arbitrary 3D flight or mixed populations. Read the analysis ↗
Hardware experiments
From robots coordinating with one another to robots responding to a person moving through their workspace.
Six robots · antipodal exchange
Each robot adjusts its speed along its prescribed path. Passage is coordinated without inter-robot communication or assigned priorities.
Open videoSix robots, a follower & a human · cooperation inference
A lightweight inference layer learns whether neighbors are cooperating from their observed motion. Robots use those estimates to adapt their response to non-cooperative agents.
Open videoVideos retain the supplied playback speed. Cooperation-inference extension with Antoun K. Salib.
Paper & resources
arXiv:2610.33271 · 2026
Benchmark results
NDD is evaluated alongside ORCA, LivePoint, and centralized and decentralized CBF-QP under the paper’s shared benchmark conditions.
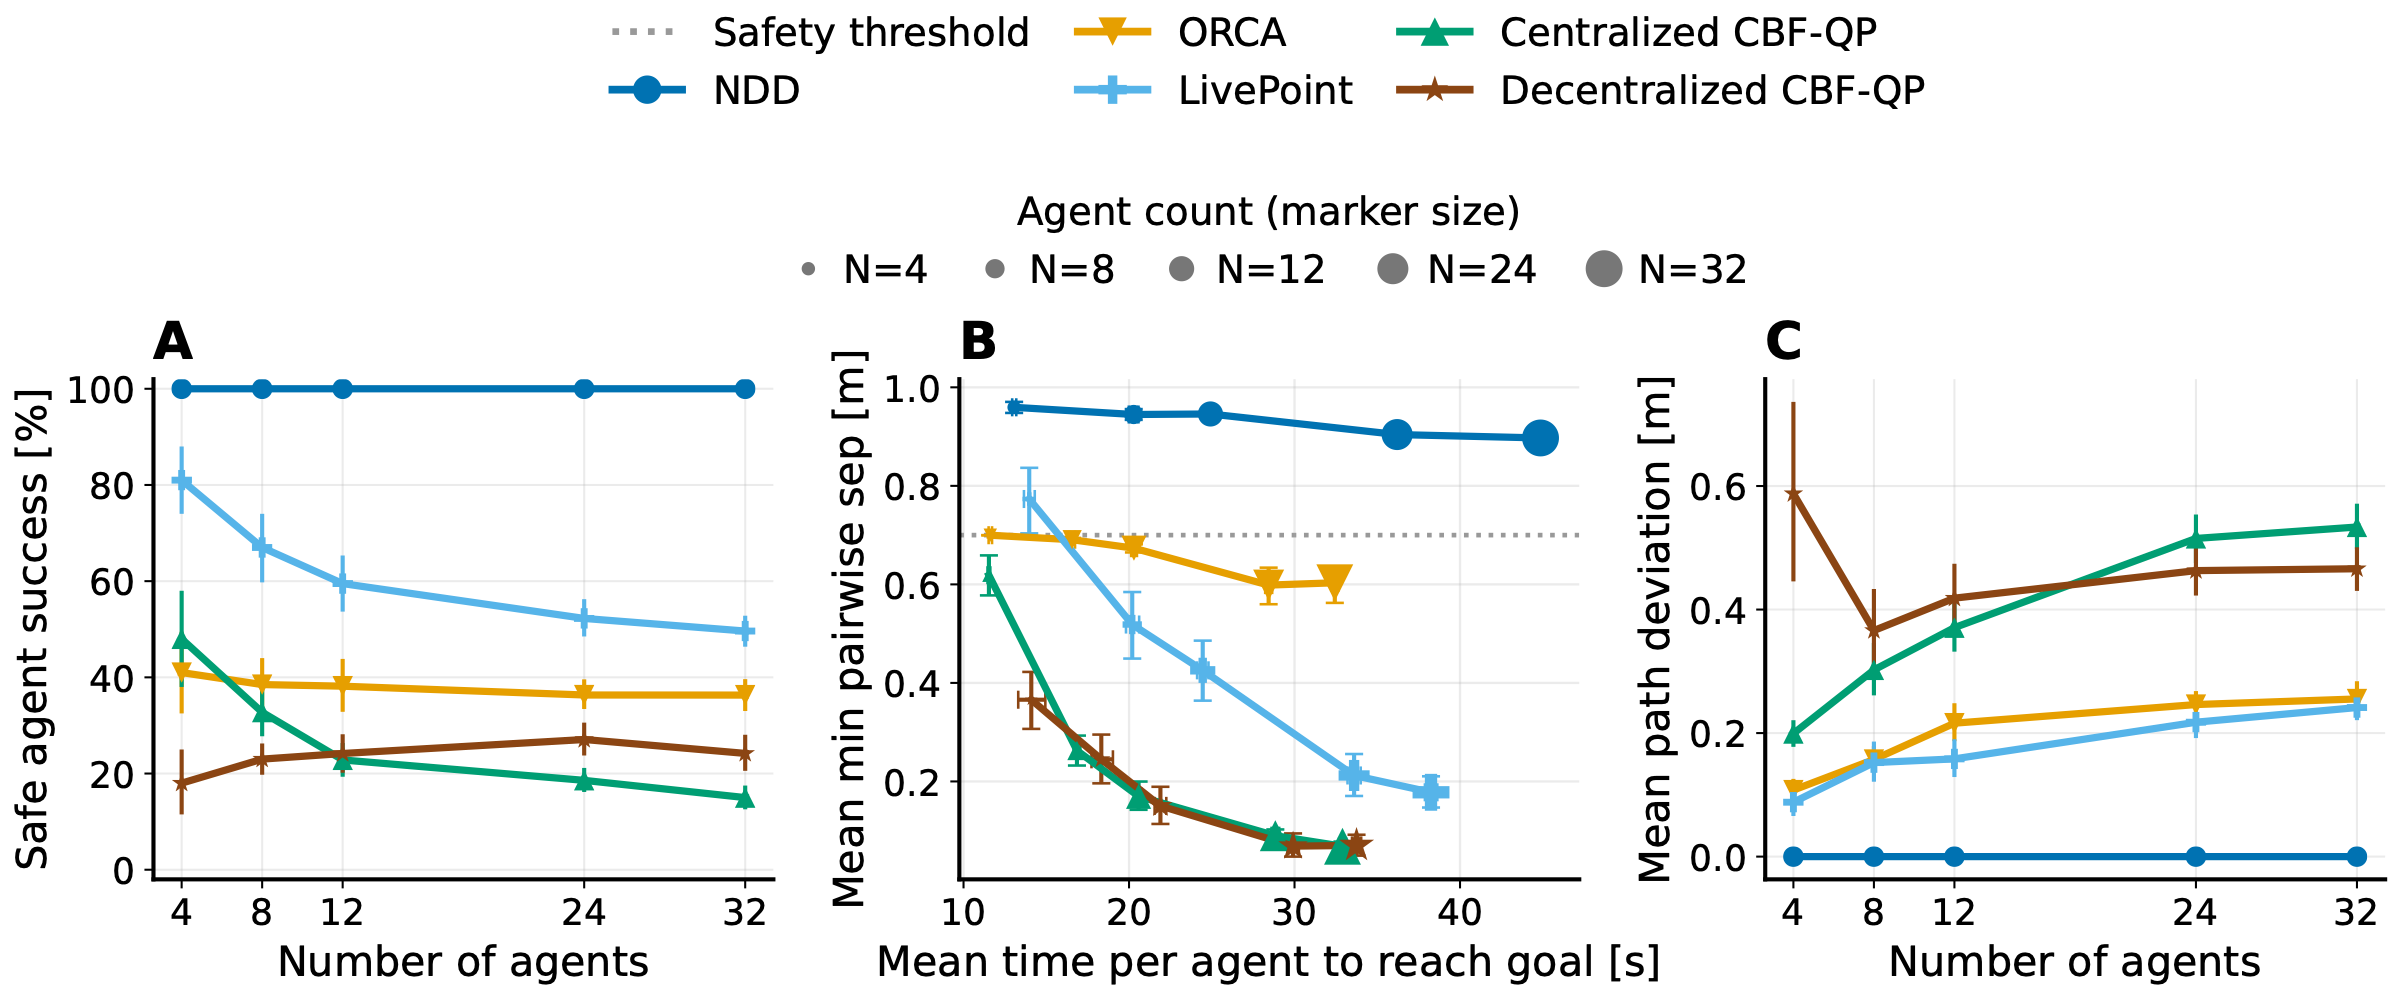
Across the reported congestion benchmark.
Conflict resolution through speed modulation.
Per agent, in separate 12- and 24-agent timing studies.
NDD evaluates locally sensed interactions without communication, centralized scheduling, or combinatorial passage-order search. Timing measurements use a single Python process on an Apple M4 Pro. Values are fleet command-generation time divided by agent count, not directly measured individual-agent latency or end-to-end sensing latency.
The means are 0.1967 ms for 12 agents and 0.2662 ms for 24 agents. These separate timing studies measure implementation cost; the figure above reports the paper’s navigation benchmark. Shorter completion times do not imply better safe navigation when separation falls below the safety threshold.